Proprioceptive Traversal
Abstract
Novel planning approach for robot navigation in vegetated environments. Instead of treating all obstacles as untraversable, our method estimates traversal costs and updates them upon collision using proprioceptive sensors.
Introduction
Traditional perception-based navigation methods are too conservative in vegetated environments. Our approach assumes all obstacles are traversable with estimated costs, then updates these costs using proprioceptive sensors upon collision.
Simulation Results
End-to-end simulation using ROS2 Humble and Gazebo demonstrates our algorithm's effectiveness in navigating through vegetated environments.
Similar work
Simon
Autonomous navigation in densely vegetated environments. Fusion of 2D and 3D perception and proprioceptive feedback enables wheeled robots to more accurately assess the traversability of their environment based on their capabilities.
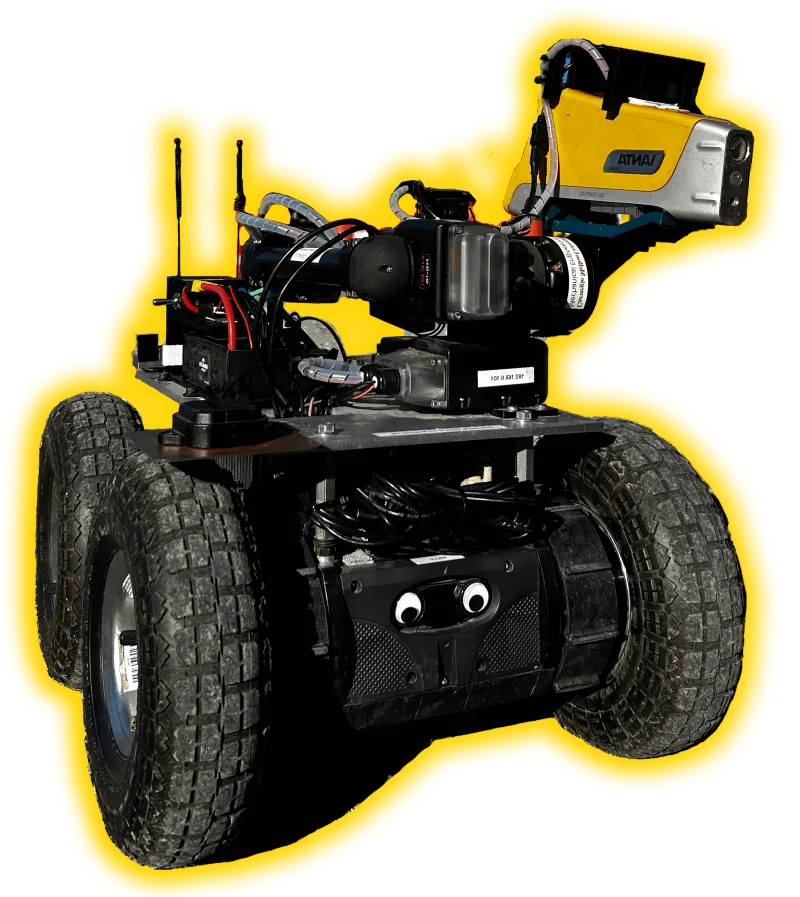
Patrick
Autonomous environmental monitoring robot for forested areas using LiDAR, camera sensor fusion, and adaptive density drive.
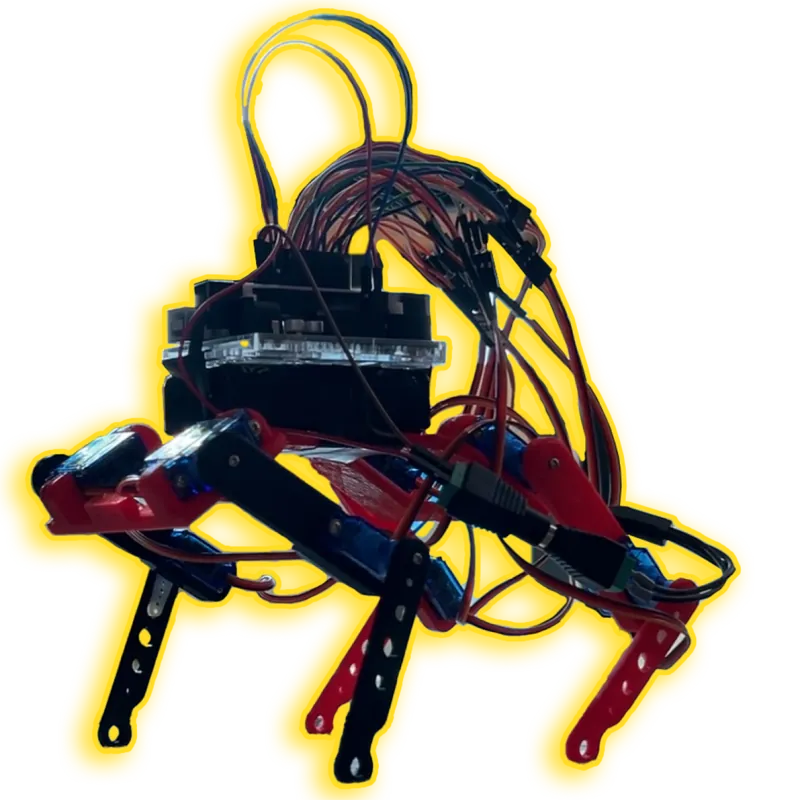
Cheap Opensource Robot Dog (CORD)
Open-source quadruped robot platform designed for educational purposes and affordable robotics research.